Story in This Work
A complete tool manipulation process involves picking up a tool, loading it into a suitable pose, and then wielding it to exploit its function.
In this work, we investigate how to enable general multi-finger robotic hands to achieve the entire pick-load-wield tool manipulation process.
Our idea is to treat the hand and the tool together as one parallel mechanism. Specifically, the hand-object mechanism consists of the hand, the object, and the generalized contact frames (GCFs), which are analgous to the mounting sites of a marionette's control strings for the hand to control object.
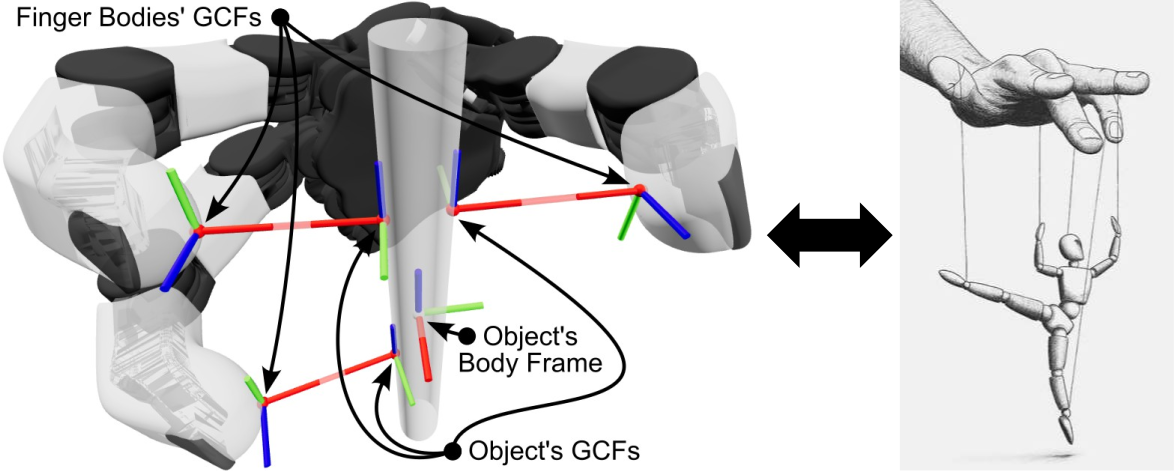
Source: instagram
Importantly, different hand-object mechanisms are constituted by common sub-assemblies.
Based on the concepts of hand-object mechanism and sub-assembly, we developed a lightweight, physically interpretable motion planning and contact estmation framework that generates a hand's tool manipulation motion with simple Cartesian velocity commands, irrespective of the hand's kinematics and geometry.
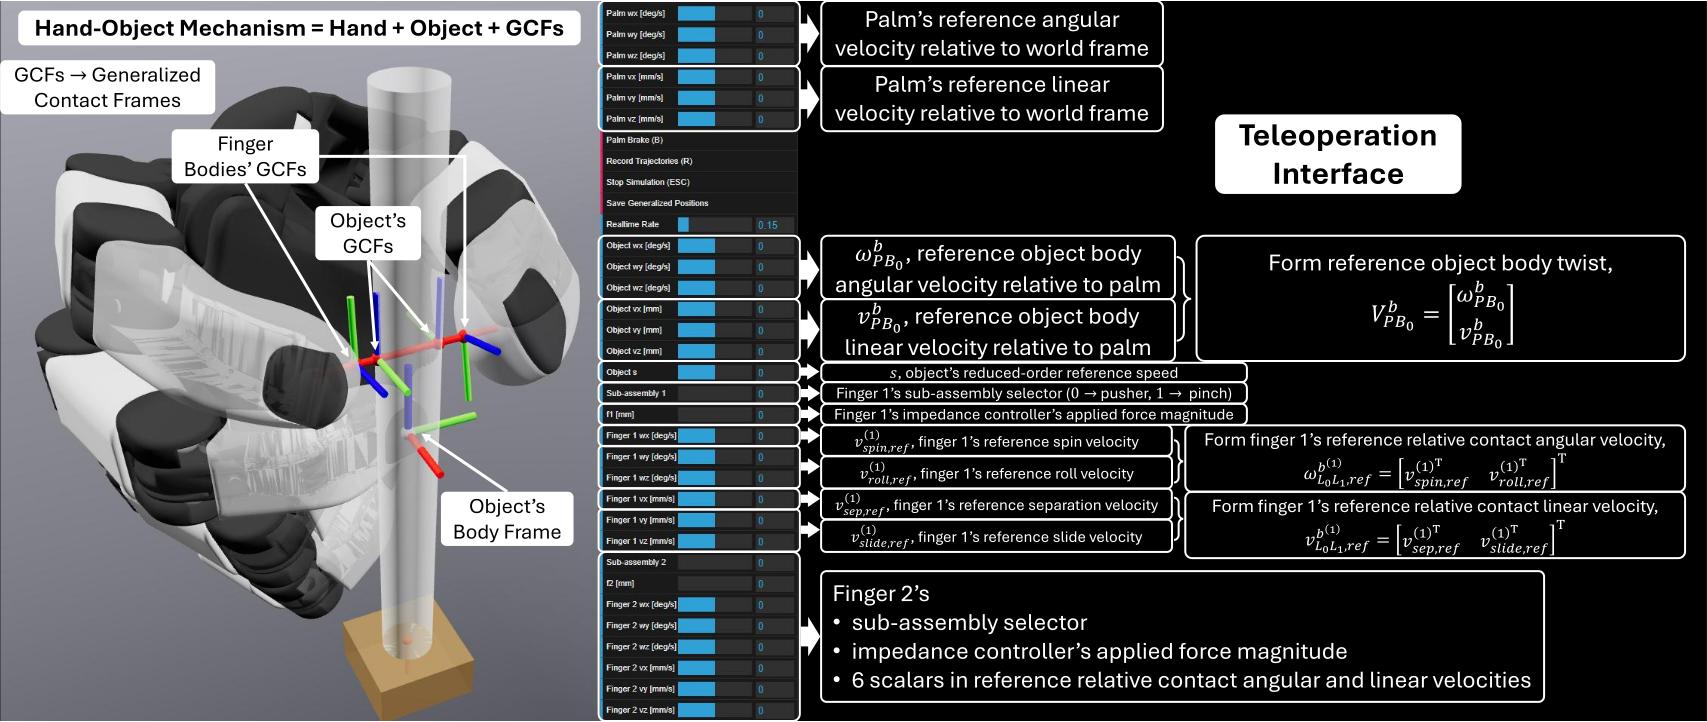
This framework immediately generalizes to other hands without the need for extensive data collection or model training, since all hands have the same Cartesian task space.
We applied our framework to five robotic hands in two tool manipulation tasks. The results show that our framework can enable all these hands to achieve the entire pick-load-wield tool manipulation process, even with simple reference trajectories commanded via a rudimentary teleoperation interface. These results demonstrate our framework's effectiveness and adaptability, motivating its future implementation on real-world hardware.