Sunyu Wang

Doctoral Student at the Robotics Institute of Carnegie Mellon University
sunyuw@andrew.cmu.edu

Education

Carnegie Mellon University
Ph.D. in Robotics 2021–2027(expected)
  • Advisors: Prof. Nancy Pollard, Prof. Jean Oh
University of Illinois Urbana-Champaign
M.S. in Mechanical Engineering 2019–2021
B.S. in Mechanical Engineering 2015–2019
profile_image.jpg

Publications

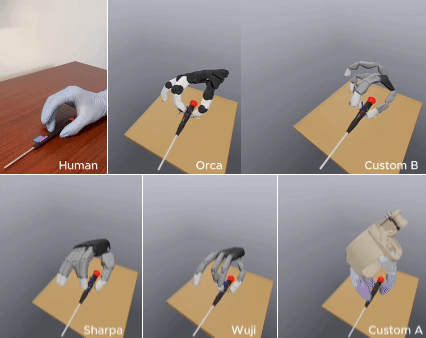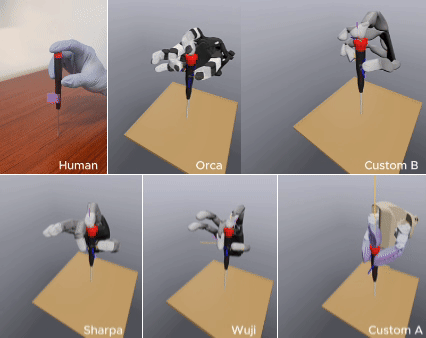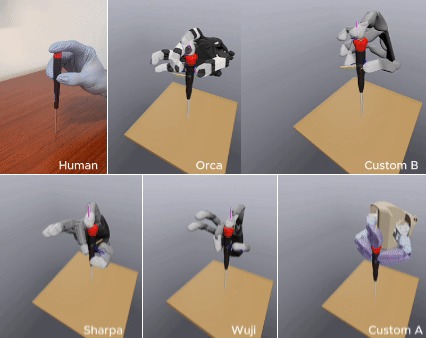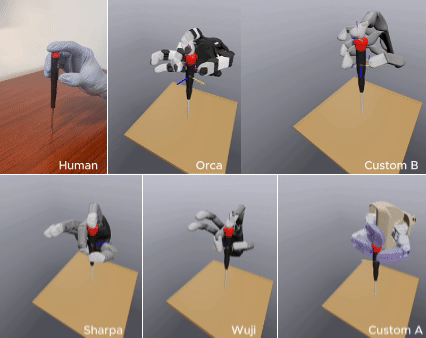
  1. Preview image for Relative Contact Velocity-Controlled Hand-Object Mechanism for Dexterous Tool Manipulation
    Relative Contact Velocity-Controlled Hand-Object Mechanism for Dexterous Tool Manipulation
    Sunyu Wang, Jean Oh, Nancy S. Pollard
    Under Review, 2026
  2. Preview image for Geodesic Tracing-Based Kinematic Integration of Rolling and Sliding Contact on Manifold Meshes for Dexterous In-Hand Manipulation
    Geodesic Tracing-Based Kinematic Integration of Rolling and Sliding Contact on Manifold Meshes for Dexterous In-Hand Manipulation
    Sunyu Wang, Arjun S. Lakshmipathy, Jean Oh, Nancy S. Pollard
    IEEE-RAS 24th International Conference on Humanoid Robots (Humanoids), 2025
  3. Preview image for The Foundational Pose as a Selection Mechanism for the Design of Tool-Wielding Multi-Finger Robotic Hands
    The Foundational Pose as a Selection Mechanism for the Design of Tool-Wielding Multi-Finger Robotic Hands
    Sunyu Wang, Jean Oh, Nancy S. Pollard
    IEEE-RAS 24th International Conference on Humanoid Robots (Humanoids), 2025
  4. Preview image for Dynamic Locomotion Teleoperation of a Reduced Model of a Wheeled Humanoid Robot Using a Whole-Body Human-Machine Interface
    Dynamic Locomotion Teleoperation of a Reduced Model of a Wheeled Humanoid Robot Using a Whole-Body Human-Machine Interface
    Sunyu Wang, Joao Ramos
    IEEE Robotics and Automation Letters, 2022
  5. Preview image for A Comparison Between Joint Space and Task Space Mappings for Dynamic Teleoperation of an Anthropomorphic Robotic Arm in Reaction Tests
    A Comparison Between Joint Space and Task Space Mappings for Dynamic Teleoperation of an Anthropomorphic Robotic Arm in Reaction Tests
    Sunyu Wang, Kevin Murphy, Dillan Kenney, Joao Ramos
    IEEE International Conference on Robotics and Automation (ICRA), 2021
  6. Preview image for A Spring-Aided Two-Dimensional Electromechanical Spine Architecture for Bio-Inspired Robots
    A Spring-Aided Two-Dimensional Electromechanical Spine Architecture for Bio-Inspired Robots
    Bonhyun Ku, Sunyu Wang, Arijit Banerjee
    IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2019
  7. Preview image for A Distributed and Scalable Electromechanical Actuator for Bio-Inspired Robots
    A Distributed and Scalable Electromechanical Actuator for Bio-Inspired Robots
    Bonhyun Ku, Yanpei Tian, Sunyu Wang, Elie Libbos, Shivang Agrawal, Arijit Banerjee
    IEEE International Electric Machines & Drives Conference (IEMDC), 2019